Process Simulate トラブルシューティング
このセクションでは、Siemens Process Simulate を使用した Resolver のインポート/エクスポート中に発生するエラーの診断と解決について詳しく説明します。
エラーはタイプ別にグループ化されており、それぞれに専用ページがあるため、原因と必要な是正措置を素早く特定できます。
Resolver のダイアログでエラーが発生した場合は、"Resolver documentation for detailed guidance" リンクを使用して、このセクション内の該当ページに直接ジャンプしてください。 In PS Connector 1.28.0 and later, use the Documentation link next to the message in the Messages panel.
このセクションの使い方
-
Resolver でインポート/エクスポートを実行します。
-
エラー メッセージが表示されたら、エラー タイトルを特定します。
-
ポップアップ内の 「Resolver documentation for detailed guidance」 をクリックするか、上記のリストから選択します。 In PS Connector 1.28.0 and later, warnings and errors collect in the Messages panel at the bottom of the Export tab instead of separate popups. Click Documentation next to a message to open its page.
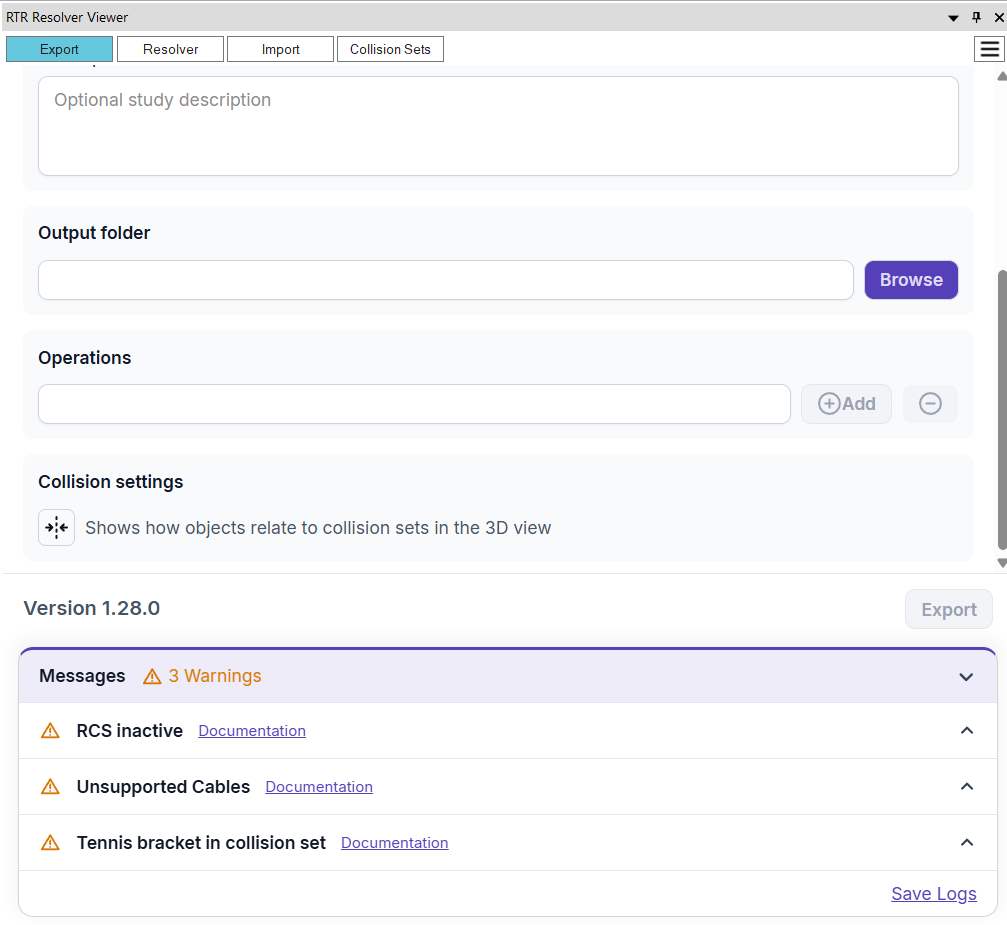
The Messages panel in PS Connector 1.28.0. The header counts the warnings, and each message has a Documentation link to its page in this section. -
エラー ページで推奨される是正措置に従ってください。
-
変更を適用した後、エクスポートを再実行します。
補足事項
- エクスポートを妨げるのはブロッキング エラーのみです。警告は一部のシナリオでは無視しても問題ありませんが、各エラー ページでそれが適切な場合を説明しています。
- エラーが不明確な場合や修正後も解消されない場合は、サポートに連絡し、以下を添付してください:
- Resolver エラー ポップアップのスクリーンショット、 (PS Connector 1.28.0 and later: a screenshot of the Messages panel)
- お使いの Process Simulate
.pszx、 - エクスポートされたログ。
エラー一覧
以下のリストには、Process Simulate に関連するすべてのエラー(PS にも影響する一般的な Resolver サニティ チェックを含む)が含まれています。完全なリファレンスとしてご利用ください。
Joint & Reachability Issues
- Too few locations
- Joint Speed Exceeds Maximum Allowed Value
- Joint limit violation
- Large joint limits
- Low velocity
- Low acceleration
- Unsupported kinematic loop detected
- Undefined kinematics
- Unreachable Locations Exported as Unassigned
- Unreachable External TCP Locations
Collision & Geometry Issues
- Missing collision sets
- Collision Set(s) missing and dynamic link attachments is enabled
- Missing self-collision rules
- Invalid collision set
- Objects not included in Collision Sets
- Dynamic devices filtered
- Unsupported cables
- Joints with missing links
- Unexportable Robot Attachments
Motion & Assignment Issues
- Unsupported motion type
- Project opened in Line Simulation Mode
- Invalid OLP Commands for Shared Targets
- Invalid object reference in OLP command
- OLP commands affecting wrong robot's state
- Unsupported OLP Command
- Speed values out of range
- Start/End Distance Validation Failed
- Start/End Distance Schedule Validation Warning
- Start and end targets are identical
- Undefined action ID references
- Device State Modified in Parallel
- Conflicting Drive Commands
- Missing Drive Command
- Mismatching Drive Command
- Cyclical Dependency in Operations
- TCP Position Mismatch
RCS & System Issues
Project & Access Issues
Tooling & Calibration Issues
非推奨 / 現行コードでは発行されません
これらのダイアログは現行のコネクタ ビルドでは表示されず、旧バージョンのユーザー向けにのみ残されています。
- Import canceled — PS-1.15.0 で削除 (2026-02-11)
- Project name missing — PS-1.12.1 で削除 (2026-01-14)
- Missing export folder — PS-1.12.1 で削除 (2026-01-14)
- Unreachable location — PS-1.24.0 で削除 (2026-07-03)
- Invalid Joint Configuration — PS-1.24.0 で削除 (2026-07-03)
- Dynamic device exported as static — PS-1.0.6 で削除 (2025-05-30)