Run
Once a RunAn instance of a study and query computed by the Engine and generates motion paths, interlocks, and/or robot task allocation and ordering. Multiple runs can be executed in parallel by using multiple a... is started, the run environment will be prepared. This starts by creating and provisioning a server in the cloud.
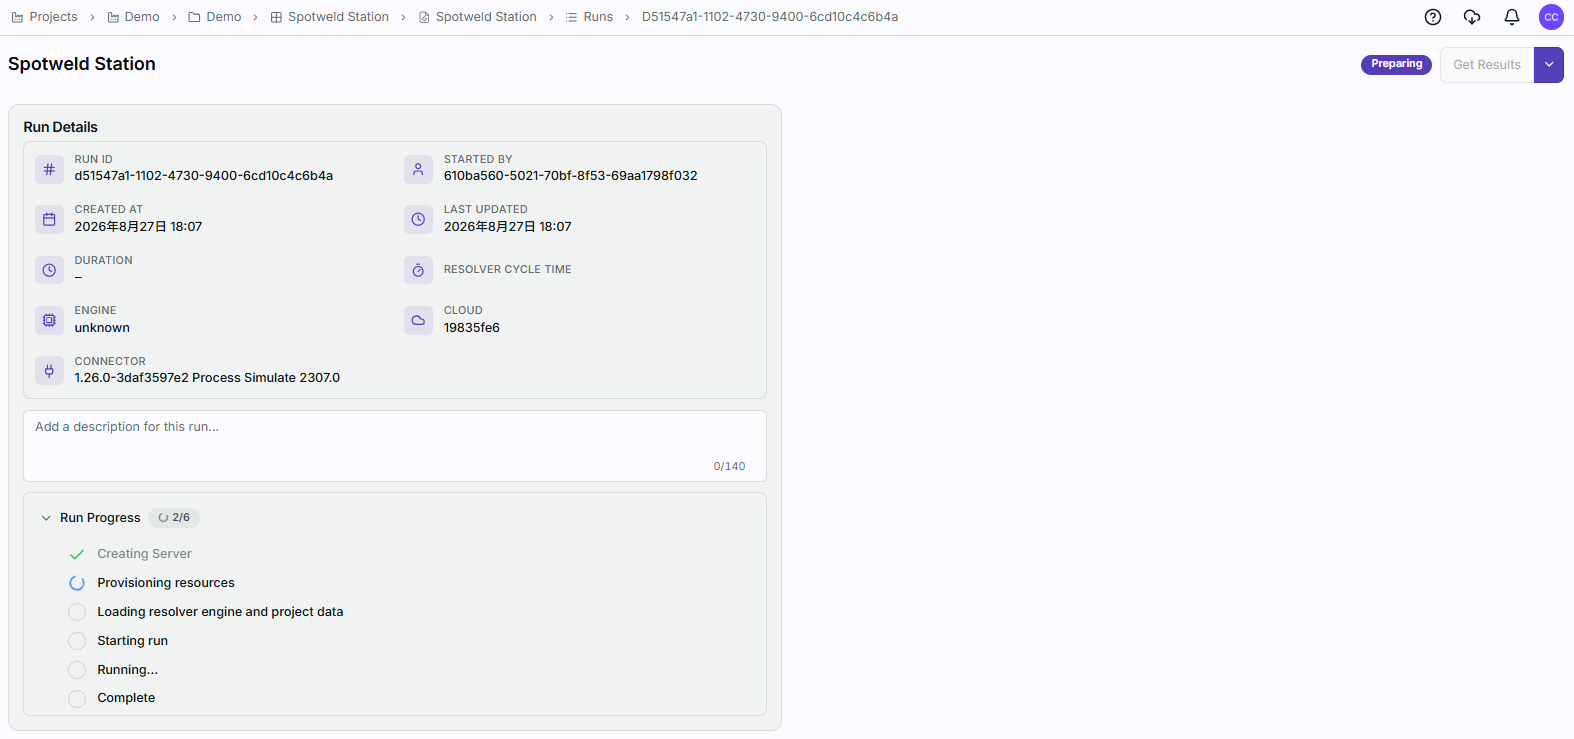
The Run Details shows information about the run and allows you to monitor its progress until the results are ready.
Run Details
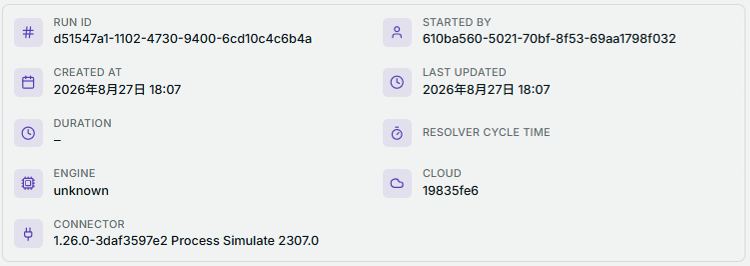
The Run Details section displays information about the submitted run, including:
Run ID: Unique identifier assigned to the run.
Started By: Identifies the user who started the run.
Created At: Date and time when the run was submitted.
Last Updated: Most recent update to the run.
Duration: Total processing time. This is populated as the run progresses.
Resolver Cycle Time: Cycle time reported by Resolver when available.
Engine: Resolver engine information.
Cloud: Cloud version used to process the run.
Connector: Connector and Process Simulate version used to submit the project.

A description can also be entered in the Add a description for this run... field to help identify the purpose of the run later.
Run Progress
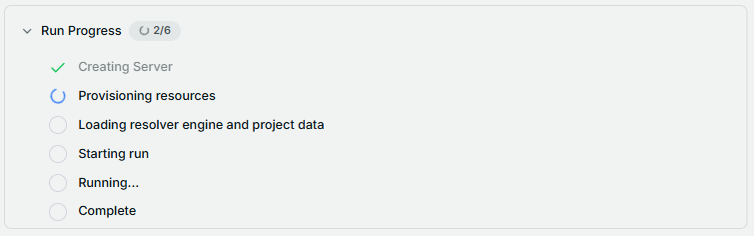
The Run Progress section shows the current processing stage.
Resolver progresses through the following stages:
Creating Server
Creates the cloud environment required for the run.
Provisioning resources
Allocates the computing resources required by Resolver.
Loading resolver engine and project data
Loads the Resolver engine and the project data submitted with the run.
Starting run
Initializes the Resolver calculation.
Running...
Resolver processes the project and performs the requested optimization.
Complete
Processing has finished and the run results are ready.
A green check mark indicates a completed stage. The blue loading indicator identifies the stage currently being processed. Stages that have not yet started are shown with an empty indicator.
For example, in the image above, Creating Server has completed and Resolver is currently Provisioning resources.
Run status

The current run status is displayed in the upper-right corner of the page. While Resolver is preparing the environment required to process the run, the status is shown as Preparing. No user action is required during this stage. Keep the run active and allow Resolver Cloud to complete the preparation process.
Get Results, Aceept Results & Stop, Stop Run
Following the provisioning process, reachability checks will happen in the engine and an initial collision-free solution will be produced. The engine will continue iterating through hundreds of thousands of possibilities to improve cycle time and path quality.
At any point in the run, the user can Get Results, Accept Results & Stop or Stop Run.

Get Results
Get Results will download the latest results without stopping the EngineThe engine (or Resolver Engine) refers to the core algorithm that is running in Resolver that takes a study and a query; generates collision free motion paths, interlocks, and task allocations; and pr.... You can import the intermediate results into the simulation software to evaluate them.
Accept Results & Stop
From the drop down menu, select Accept Results & Stop to stop the run and get the latest results. You will not be able to resume the run. The process of retrieving the results can take a few seconds. A popup message will appear in the lower right corner of the screen when the results are ready.
Stop Run
From the drop down menu, select Stop Run to stop the run without generating any results. Since no results are generated, you will not be able to download any results.
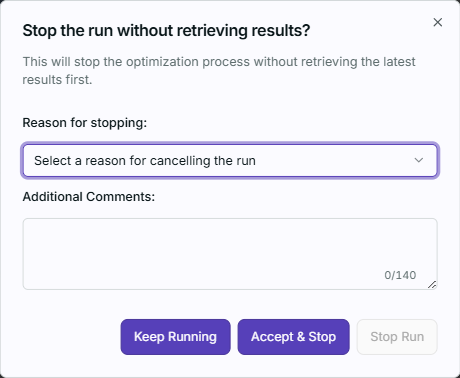
Please select the reason for stopping the run and provide any additional feedback that will allow us to improve the product.
Results
Reachability
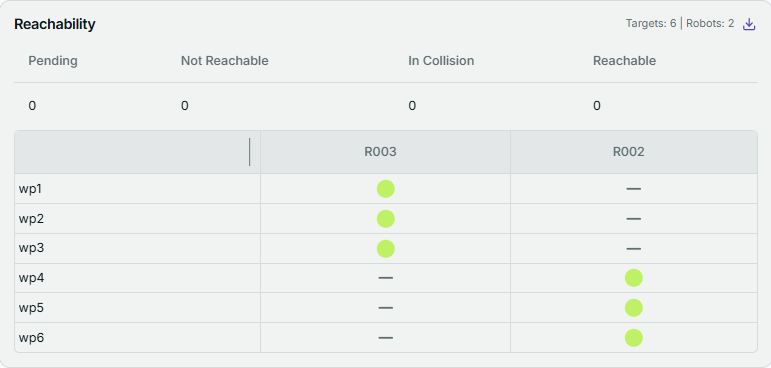
Resolver will check if robots are able to reach their assigned targets by generating actual motion paths. Within minutes, a table will be generated detailing which robots can reach which assigned points. The table can be downloaded in CSV format for you to use elsewhere in your planning and engineering processes.
The different states displayed on the table are:
-
Pending (⌛): the Engine is calculating reachability.
-
Not Reachable (red): the target is not reachable.
-
In Collision (yellow): the target is reachable but only through a collision.
-
Clearance Violation (yellow-green): the target is reachable but only through a clearance violation
-
Reachable (green): the target is reachable without collision.
Paths
Details on the paths of the current solution are summarized in this section.
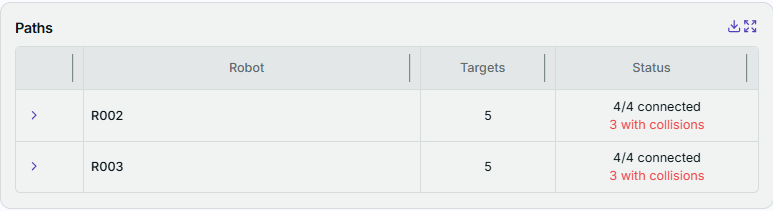
The path information can be expanded to review its motion and collision details
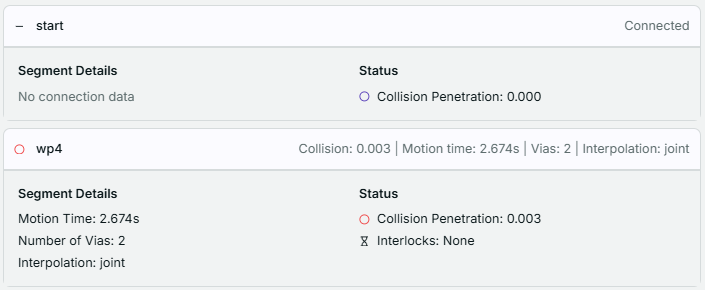
Path Summary: The summary provides key information about the calculated motion.
For example:
Collision: 0.003 | Motion time: 2.674s | Vias: 2 | Interpolation: joint
Segment Details
The following information can be reviewed in the Segment Details:
Motion Time : Estimated required for the robot to complete the motion Number of Vias : Number of intermediate via points used to get from the previous target to the current target Interpolation : Interpolation used for the motion, such as joint, linear, etc.
Status
The Status section displays information related to collision and whether an interlock signal exists in the segment
Collision Penetration : Indicates the amount of overlap detected between collision geometries along the caluclated trajectory
A non-zero collision penetration does not necessarily mean that the path is unusable. Review the collision location and the project's configured collision requirements or tolerances before determining whether corrective action is required.
Interlocks: Indicates whether there is an interlock signal in the segment. It would indicate one of the following:
None : No interlock signal required in the segment
Send : A send interlock signal is required in the segment
Wait : A wait interlock signal is required in the segment
Cycle Time Estimate
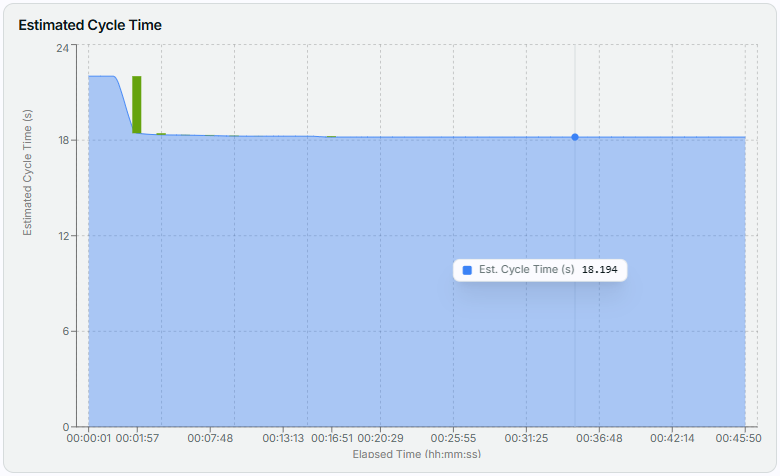
A graph showing the total cycle time estimate for the latest results is updated while the Engine is iterating and finding solutions with the lowest cycle time. The current iteration's cycle time is on the y-axis and the run's elapsed time on the x-axis.
Results Preview
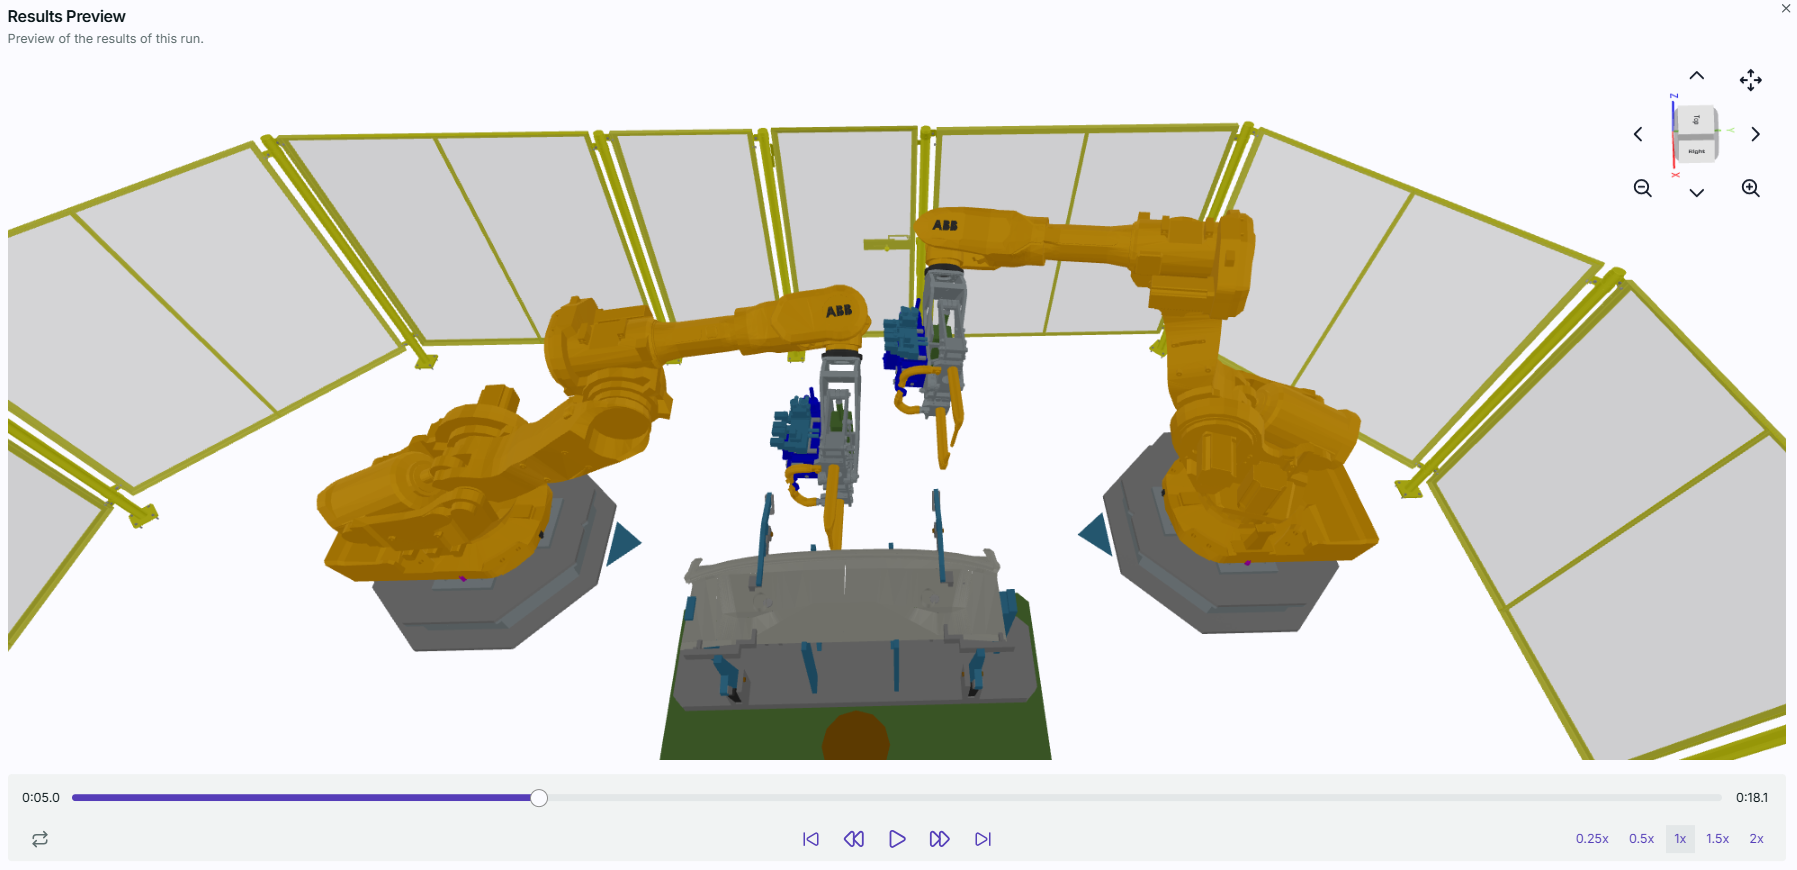
Results Preview allows you to see how the run is going before it completes. Click on Get Current Results to load the latest data, then expand the Results Preview window and watch a simulation of the generated paths and interlocks without having to import back to the simulation tool. Please note, only objects that are defined as part of the collision set will appear in the geometry of the scene in the preview. If an object does not appear in the scene and you would like it to be considered in the collision set, you need to define it in the collision sets of your simulation tool prior to export to Resolver.